2026 - nowtechnical manager
Modular Robotics Software Platform for Autonomous Agricultural Machinery
A modular software stack for autonomous farm machines: perception, navigation and fleet tooling. Łukasiewicz PIT internal R&D program.
Robotics & AI · I make machines that see, plan and find their way
01 · about
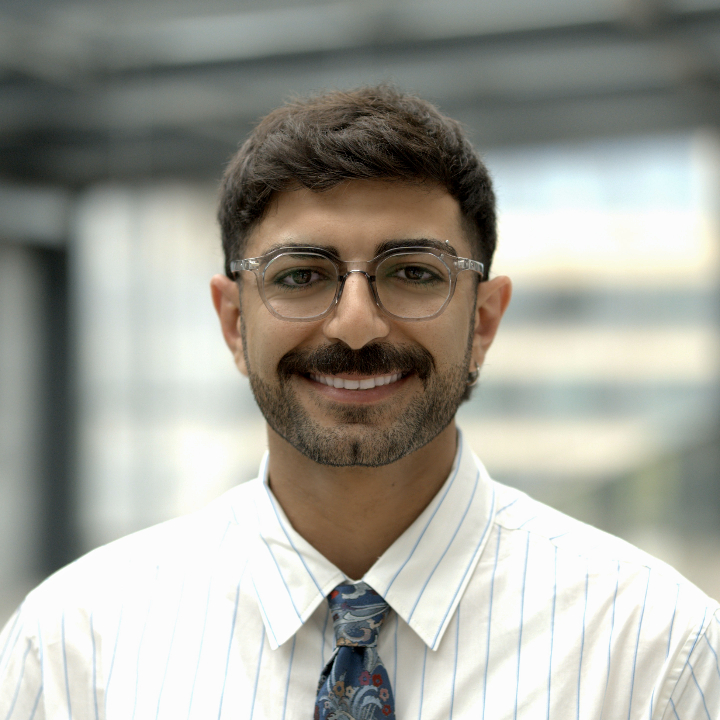
Hey, I'm Iman Esfandiyar, a robotics engineer and researcher based in Poznań, Poland. Since 2012 I've been working on computer vision, motion planning and control for autonomous mobile robots, mixing classical robotics with modern AI, in both academia and industry.
These days I'm doing a PhD in robotics at Poznan University of Technology and working as Chief Specialist in Robotics & AI at Łukasiewicz Research Network, Poznań Institute of Technology, where I lead the software and AI side of autonomous agricultural machinery.
Along the way I've been a researcher, developer and technical lead on national and EU projects, shipping software for industrial robots, autonomous city buses, farm robots and drone swarms.
02 · experience
Łukasiewicz Research Network · Poznań Institute of Technology
Artificial Intelligence Development department. Technical management plus plenty of hands-on work: autonomous agricultural robotics, perception pipelines and edge-to-cloud robot software.
Poznań University of Technology
Research and teaching in automatic control and robotics; PhD research on dense mapping and traversability for field robots.
ROGOŻ Sp. z o.o.
Led development of autonomous drone-swarm systems: swarm management and monitoring software for photovoltaic-farm inspection, drone shows and critical-infrastructure security.
Poznań University of Technology
Advanced driver-assistance system for articulated urban buses: sensor fusion, state estimation, planning and control. ROS packages in C++ on Linux.
Spadana Co
Vending-machine production line management and mechanical system design.
Azad University of Damavand
Coordinated the rescue-robot research group: mechanical design, modular electronics, embedded systems and robot communication.
03 · projects
all projects with details, videos and articles →
A modular software stack for autonomous farm machines: perception, navigation and fleet tooling. Łukasiewicz PIT internal R&D program.
EU Horizon Europe meta-OS spanning IoT, edge and cloud. Built the autonomous farm-robot use case and resilient edge-to-cloud communication for agricultural robots.
Computer-vision pipeline for crop and weed detection trained on synthetic data generated from digital twins of fields.
EU Digital Europe facility for validating AI in agriculture; plant detection and autonomous farm-robot development.
Advanced driver-assistance for precise maneuvers of articulated Solaris city buses: GNSS-based guidance, state estimation and control, validated in field tests.
Reconfigurable drone-swarm technology for PV-farm inspection, drone shows and digital security of critical infrastructure: swarm management and monitoring software.
04 · publications
I. Esfandiyar, D. Belter · IEEE Access, vol. 13, pp. 204285-204314 · doi:10.1109/ACCESS.2025.3638877
I. Esfandiyar, K. Młodzikowski · IoTAI 2025, The Second International Conference on IoT-AI, pp. 27-34 · doi:10.5281/zenodo.17735730
A. Jaworski, M. Kotlinski, I. Zrazinska, X. Masip-Bruin, J. Garcia, I. Esfandiyar · GIECS 2024, Springer CCIS vol. 2328, pp. 119-133 · doi:10.1007/978-3-031-78572-6_8
I. Esfandiyar, K. Ćwian, M. R. Nowicki, P. Skrzypczyński · Remote Sensing, vol. 15, iss. 11, 2938 · doi:10.3390/rs15112938
full texts, BibTeX & RIS · full list → Google Scholar · ORCID
05 · contact
Always happy to talk research collabs, R&D consulting, or field robots in general.
Download full CV